
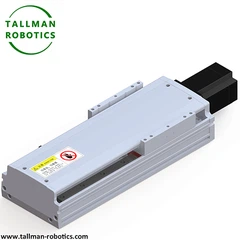


What is Telescopic Manipulator Module?
A telescopic manipulator module is a self-contained, pre-engineered subassembly combining a telescoping reach mechanism with an integrated end-effector interface, designed to be bolted into a larger machine, workcell, or vehicle platform as a modular building block rather than a standalone operator-controlled unit. Compared to a complete telescopic manipulator system, the "module" designation emphasizes its packaged, plug-in nature-supplied with standardized mounting interfaces and electrical/control connections so integrators can add reach-and-grasp capability without designing the mechanism from scratch.
Structure
The module houses nested telescoping sections driven by an internal electric screw, hydraulic cylinder, or chain mechanism, terminating in a standardized tool-mounting flange or quick-change interface for attaching grippers, hooks, or other end-effectors. A compact drive housing at the base integrates the motor, gearbox, and position feedback sensors, with a defined mounting footprint (bolt pattern, electrical connector, communication port) allowing the entire module to be installed as a unit into the host equipment's structure and control architecture.
Selection Considerations
Key factors include stroke length, payload capacity through full extension, mounting footprint and orientation compatibility with the host machine, end-effector interface standard, control signal type (analog, digital I/O, fieldbus), integration complexity, and available feedback resolution for closed-loop positioning. Envelope dimensions (retracted and extended) must be checked against the host machine's available installation space and clearance requirements.
Applications
Telescopic manipulator modules are used in modular robotic workcells, mobile robot payload systems, automated guided vehicles (AGVs) requiring retrieval capability, custom material handling machines, and OEM equipment where manufacturers want to add reach-and-grasp functionality without engineering a custom mechanism.
Installation Considerations
The host structure must provide a mounting surface matching the module's bolt pattern and rated to absorb reaction loads at full extension. Electrical and communication connectors should be mated and secured per the module's interface specification. End-effector attachment should be verified for correct alignment, and the integrator should run full-stroke test cycles under representative payload to confirm smooth operation before final commissioning into the host system.
Here we introduce Telescopic Manipulator Module, TMTH5 with data sheet to you as follows:
You are welcome to watch more projects or visit our video gallery by Youtube: https://www.youtube.com/@tallmanrobotics
|
Model No |
Motor Power(W) |
Body Width (mm) |
Repeatability (mm) |
Ball Screw Rod (C7) |
Max Load (kgs) |
Stroke (mm) at Max speed (mm/s) |
Speed (mm/s) at Max stroke (mm) |
Rated Thrust |
||
|
Out dia (mm) |
Lead (mm) |
Horizontal |
Vertical |
|||||||
|
TMTH5 |
100W |
54 |
±0.01 ±0.005 |
12 |
2 |
23 |
10 |
600mm at 100mm/S |
60mm/S at 800mm |
854 |
|
5 |
30 |
10 |
600mm at 250mm/S |
150mm/S at 800mm |
341 |
|||||
|
10 |
15 |
5 |
600mm at 500mm/S |
300mm/S at 800mm |
170 |
|||||
|
20 |
10 |
2.5 |
600mm at 1000mm/S |
600mm/S at 800mm |
85 |
|||||
|
200W |
2 |
30 |
10 |
600mm at 100mm/S |
60mm/S at 800mm |
170 |
||||
|
5 |
30 |
10 |
600mm at 250mm/S |
150mm/S at 800mm |
682 |
|||||
|
10 |
28 |
8 |
600mm at 500mm/S |
300mm/S at 800mm |
340 |
|||||
|
20 |
15 |
5 |
600mm at 1000mm/S |
600mm/S at 800mm |
170 |
|||||
|
400W |
2 |
30 |
10 |
600mm at 100mm/S |
60mm/S at 800mm |
3389 |
||||
|
5 |
30 |
10 |
600mm at 250mm/S |
150mm/S at 800mm |
1353 |
|||||
|
10 |
30 |
10 |
600mm at 500mm/S |
300mm/S at 800mm |
674 |
|||||
|
20 |
22 |
8 |
600mm at 1000mm/S |
600mm/S at 800mm |
337 |
|||||
|
10 |
110 |
33 |
800mm at 500mm/S |
233mm/S at 1250mm |
1050 |
|||||
|
20 |
60 |
16 |
800mm at 1000mm/S |
467mm/S at 1250mm |
528 |
|||||
|
32 |
50 |
10 |
800mm at 1600mm/S |
747mm/S at 1250mm |
380 |
|||||


FAQ
What's the difference between a telescopic manipulator module and a telescopic manipulator?
A module is a packaged, plug-in subassembly designed for integration into a larger machine, while a complete manipulator is typically a standalone system with its own base, controls, and operator interface.
What mounting interfaces do telescopic manipulator modules typically use?
Most modules feature a standardized bolt pattern and connector interface at the base, along with a quick-change or flange-style tool mount at the tip for attaching various end-effectors.
Can a telescopic manipulator module be used with any end-effector?
Compatibility depends on the module's tool-mounting interface standard; grippers or tools must match the specified flange pattern and electrical/pneumatic connections, or an adapter may be required.
How much engineering integration is required to add a telescopic manipulator module to existing equipment?
Since modules come pre-engineered with standardized interfaces, integration typically involves structural mounting, electrical/control wiring, and software configuration rather than custom mechanism design.
What control signals do telescopic manipulator modules commonly accept?
Common options include simple digital I/O for basic extend/retract commands, analog position signals, or fieldbus protocols like CANopen or EtherCAT for integration with more sophisticated automation systems.
Hot Tags: telescopic manipulator module, China telescopic manipulator module manufacturers, suppliers, factory, Endless Belt Linear Unit, Belt Drive Linear Stage, Servo Belt Actuator, Linear Belt Drive Actuator, Fast Acting Linear Module


